
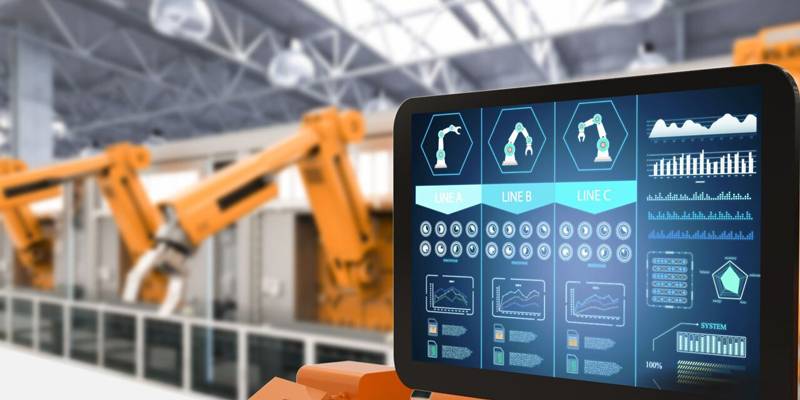
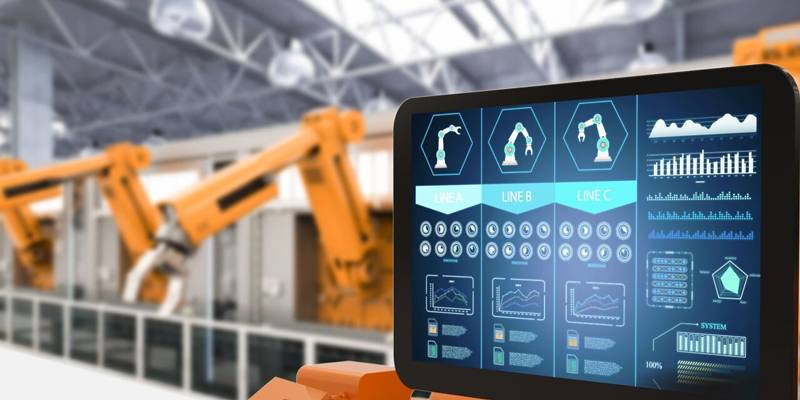
With the rapid development of industry and high-precision processes, motion control in mechanical automation has replaced many repetitive manual tasks, and intelligent production lines have greatly improved enterprises' efficiency. In different production environments, the performance of industrial robot grippers plays a vital role; complex operations such as flexibility, automatic control, automatic feedback, and intelligent grasping are central to a company's core technology and production efficiency.
Trinamic stepper-servo controllers can implement motor torque control. They are particularly suitable for applications such as robot grippers, industrial machine grippers, laboratory automation, and cap opening and bottle-cap twisting.
How Trinamic implements torque control
Torque (force) control: taking Trinamic's integrated stepper-servo closed-loop controller as an example, it supports serial or CAN communication. The torque value is set through the TMCL-IDE host software; commands are uploaded via the software, such as setting the minimum current/maximum current. When the motor operates, its current varies between the maximum and minimum values; the larger the load, the larger the current value. When we need force control, we can use the encoder feedback value to set an appropriate value. When the external force reaches the set value, an output signal is triggered.
Flexibility and Safety
For different objects, our concern is that the output force may damage the gripped object. We can set the maximum force according to actual requirements, i.e., its maximum current value; control of the external force applied to the gripper is also quite flexible. We can also use a program to make it stop automatically when it reaches the set maximum value.
While the gripper is working, the program continuously monitors its force and prevents the output force from exceeding a certain value. When it reaches this value, the motor stops and always maintains this force without crushing the object, ensuring object safety and improving gripper performance.
Summary:
Trinamic's motion control and host software allow you to easily master its control method and complete projects faster. With torque control for stepper servos, while achieving closed-loop position and speed control, it continuously emits signals according to the load. We can also make this signal trigger more actions, such as stopping, holding for a period of time, reversing, etc. When the signal ends, it returns to the original position, which is more conducive to the flexibility and safety of grippers or other applications.